NEMO
A student-developed platform for bipedal locomotion, with Unitree actuation, AMD computing, and a learned walking policy.
Powered by
Hardware & controls
Mechanical design
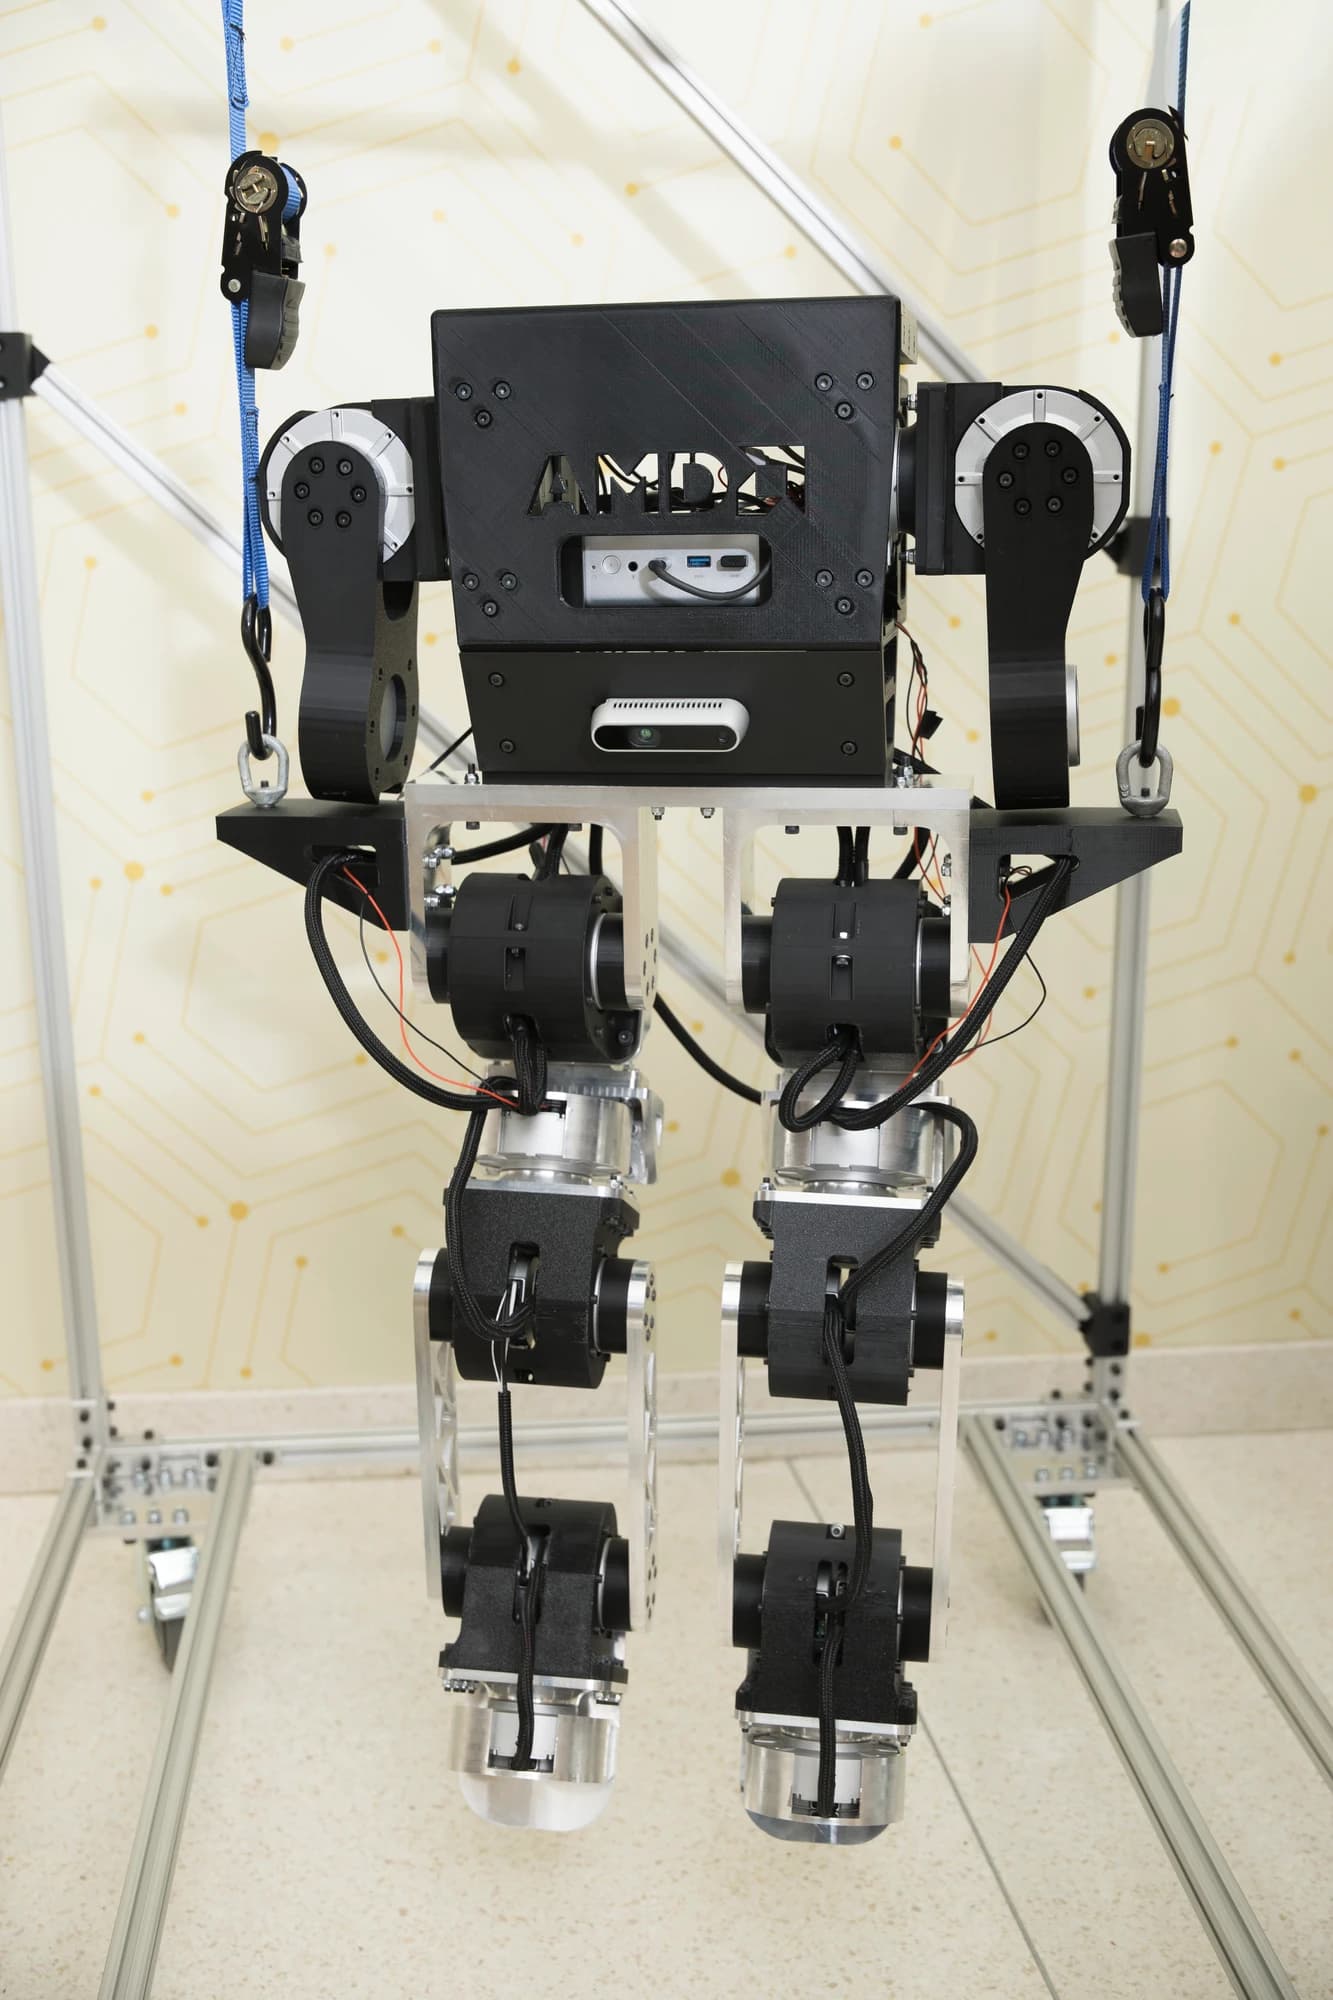
A bipedal platform with six degrees of freedom in each leg, using Unitree actuators to move the hips, knees, and ankles.
- Leg degrees of freedom
- 12 (6 per leg)
- Actuators
- 18 total
- Actuator Model
- Unitree GO-M8010-6
- Peak Torque
- 23.7 Nm
- Articulation
- Hip, knee, and ankle
NEMO in motion
Mid-air walking simulation
Watch on YouTubeFirst ground walking tests
Watch on YouTube